Two hose paths, one moving envelope
A specialist thermoplastic placement and winding application recorded with a 48 + 70 dual-hose Series 4 telescopic route on a Comau N-170-3.0.
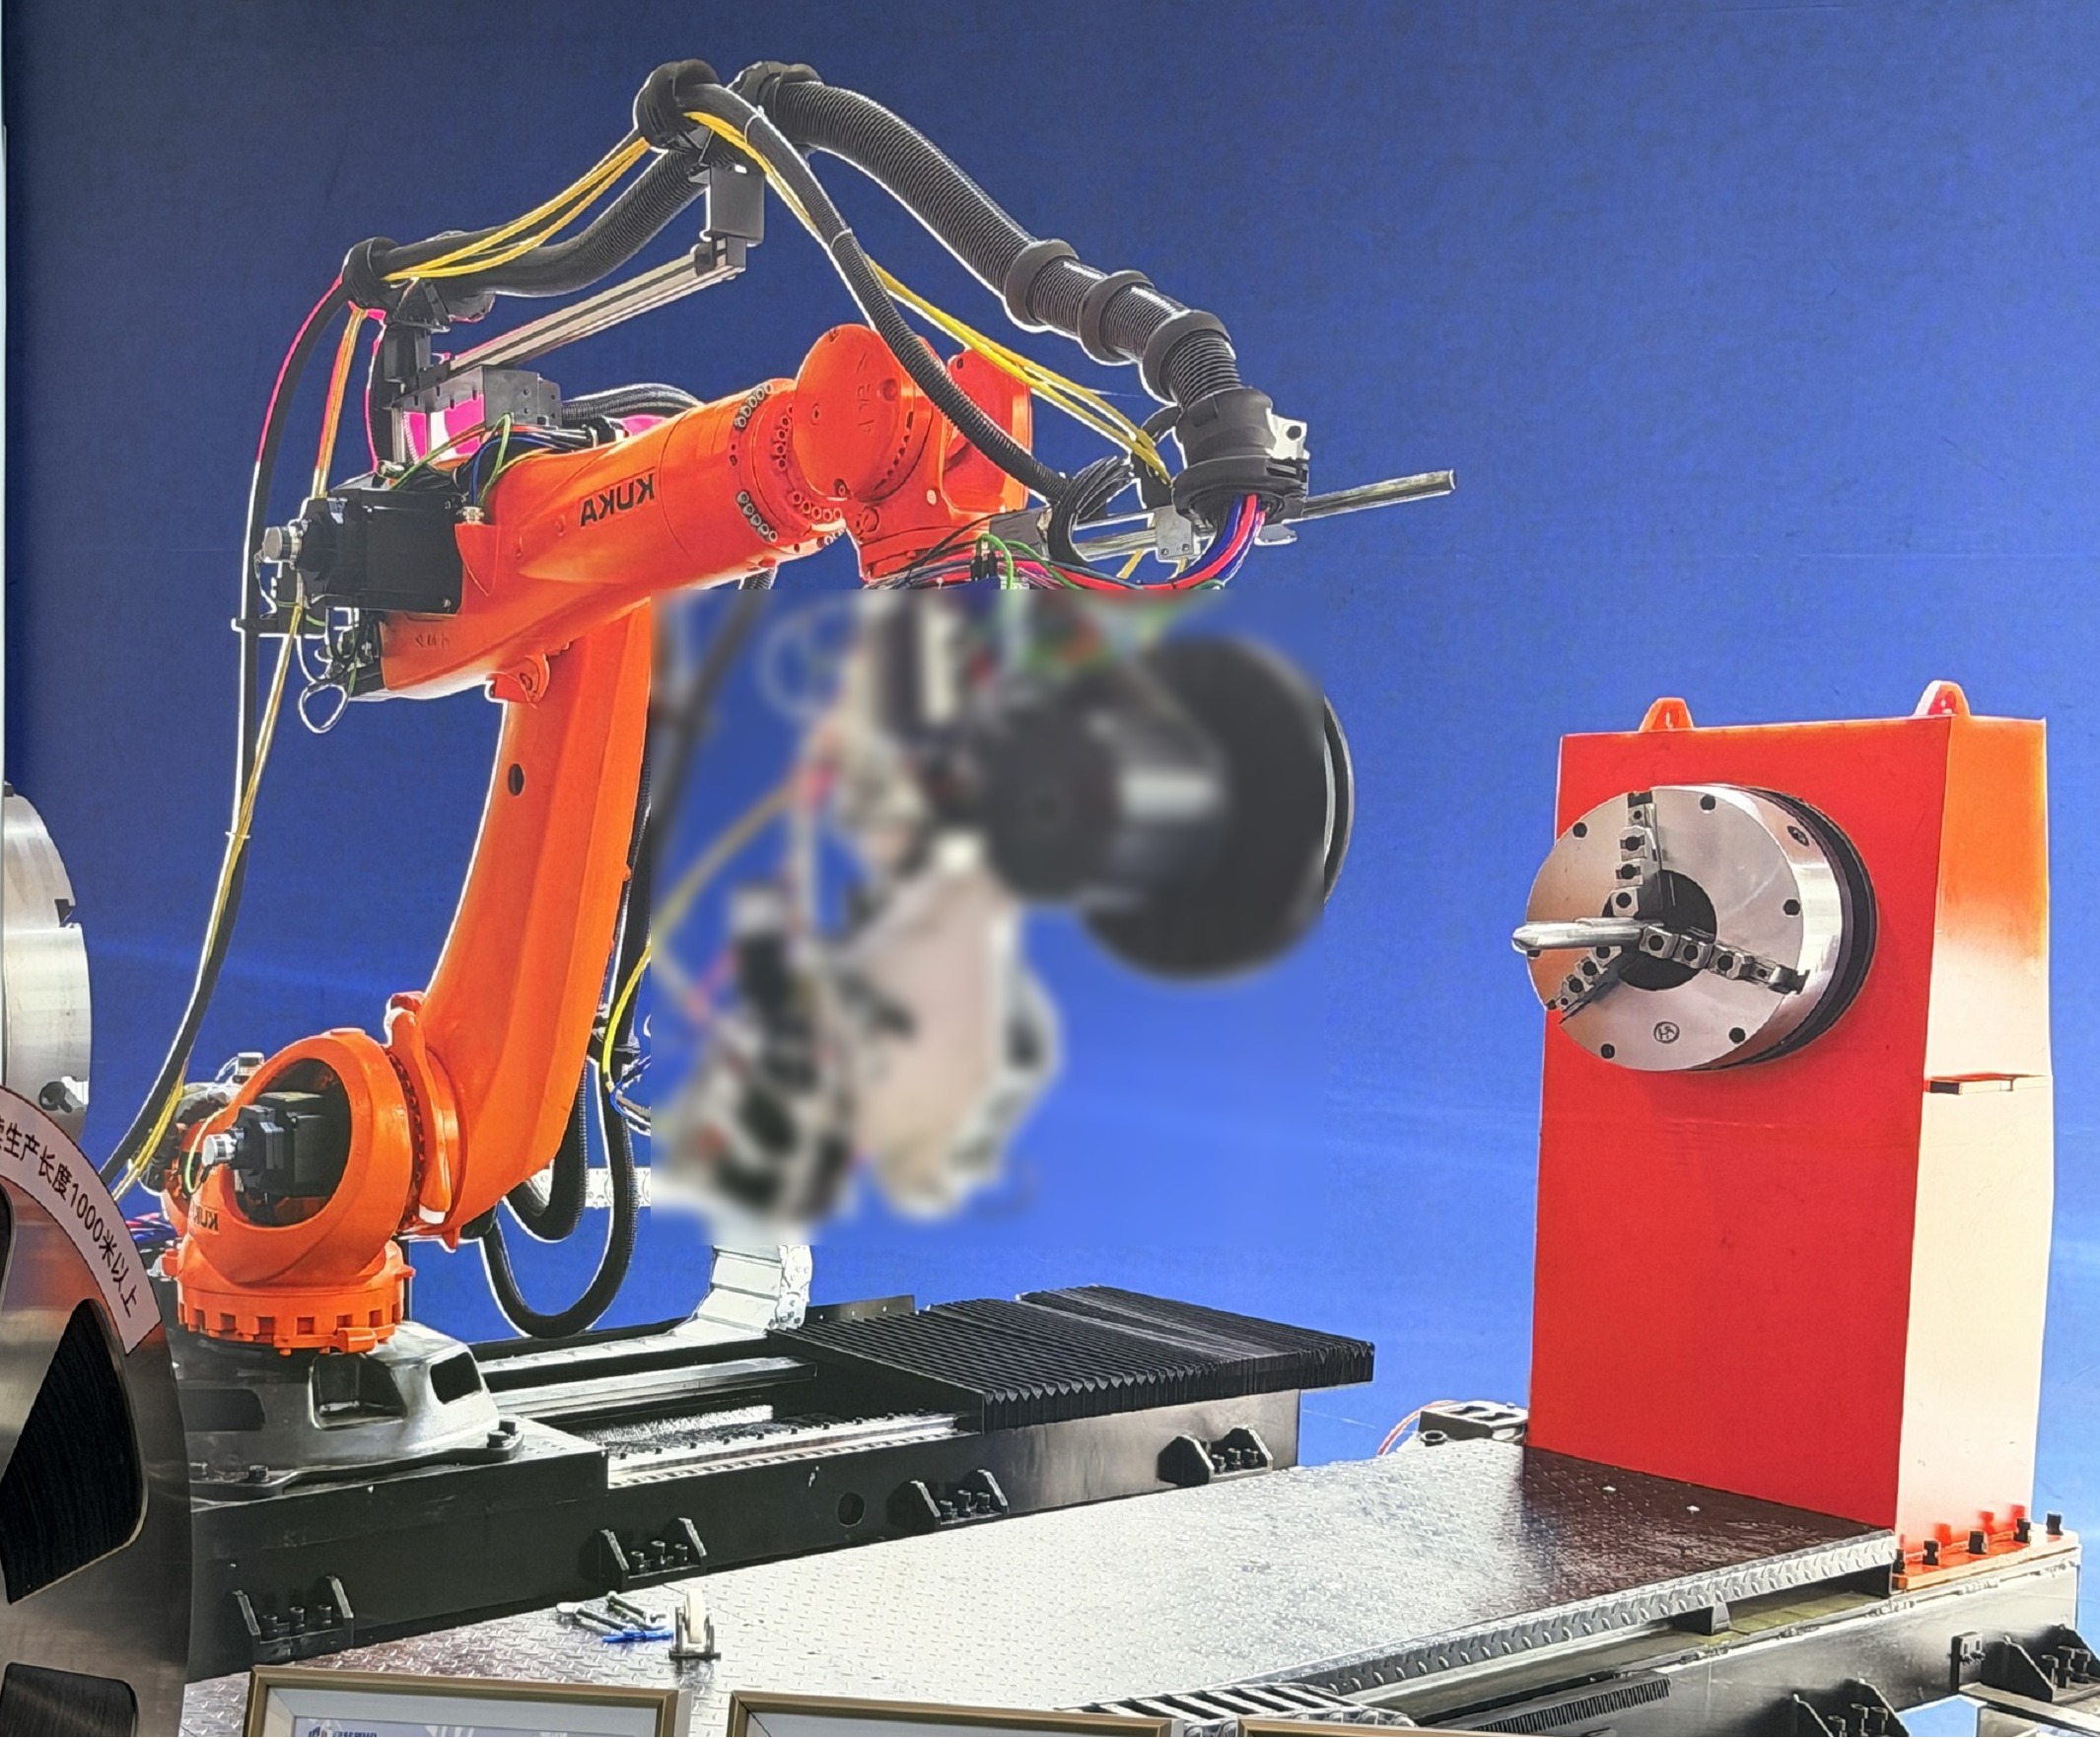
A specialist thermoplastic placement and winding application recorded with a 48 + 70 dual-hose Series 4 telescopic route on a Comau N-170-3.0.
What made this record useful.
The public value is not a part number. It is the combination of a robot family, a process environment and a route architecture that can be discussed with the people who will install and maintain the line.
| City | Wuhan, Hubei |
|---|---|
| Client type | Equipment manufacturer (anonymized) |
| Process | AFPT thermoplastic placement / winding |
| Robot | Comau N-170-3.0 · several |
| Dresspack record | 48 + 70 dual-hose Series 4 telescopic |
| Record date | TBC |
| Disclosure | Public fields; customer identity withheld |
The questions this record raises.
- Dual-hose separation and bend radius
- Thermal exposure around the tool
- Telescopic storage through the winding path
- Access for inspection and replacement
From a public record to a released interface.
Read the public record
Start with the robot, process and configuration. Do not infer a diameter or bracket geometry from the record alone.
Map the duty
Reconstruct the actual tool cycle, the high-risk zone and the inspection window for the new project.
Check the envelope
Use the real robot model and tool to check anchors, bend radius and collision through the full motion.
Release the interface
Agree the drawing, BOM and service route before a trial installation or batch release.
What must be checked before handover.
- Interface: flange, fixed points and tool-side connection do not interfere through the full cycle.
- Bend radius: the assembled bundle stays within its allowed minimum radius.
- Motion margin: maximum extension does not pull tight; minimum retraction does not stack the bundle.
- Protection: the outer structure covers the high-risk zone and leaves the inspection path open.
- Fasteners: anchors and brackets are checked for dynamic load and access.
- Maintenance: the wear part, inspection interval and replacement path are documented for handover.
Open the system or application behind this record.
Use the record as a question, not an answer.
Share the model and the motion. We will tell you what changes.