Real interfaces. Useful records.
A selection of public project records from automotive and equipment-manufacturing contexts. Customer names, prices and proprietary drawings are deliberately excluded; the robot, process, configuration and date are kept.
Filter by the work, not the customer.
08 records · public fields only
 Spot + handling
Multi-process line, one interface logic
A KUKA-heavy automotive parts line linking spot welding and handling duties. The public configuration combines a Series 4 barrel with a Series 3 spring route across 49 robots.
 Steel spot
 welding with tool-change clearance
A high-density KUKA line where spatter protection and tool access had to coexist. The public record uses Series 4 for the outer protection route and Series 3 for spring compensation.
 Quick change
Spatter protection around a quick tool change
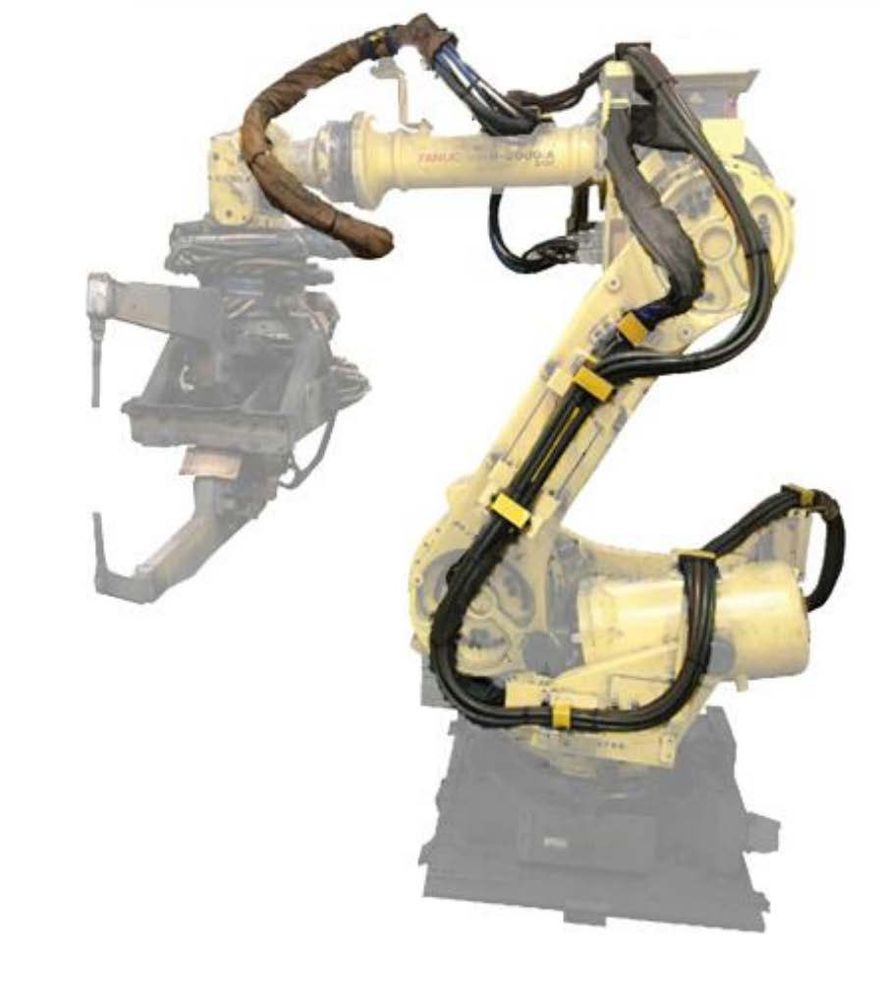
A FANUC spot-welding duty with a quick-change tool interface. The public configuration uses a Series 4 barrel; the engineering question is how the barrel behaves during the change, not only while welding.
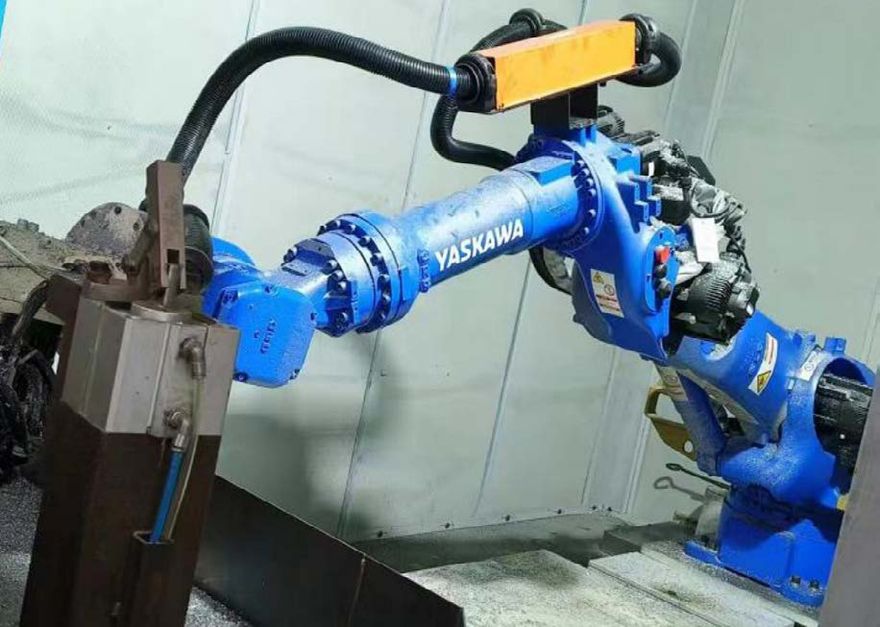 Handling
Long-reach handling with controlled rebound
A KR420 handling duty requiring the cable route to follow a large working envelope. The public record uses a Series 3 external spring with a cover route across twelve robots.
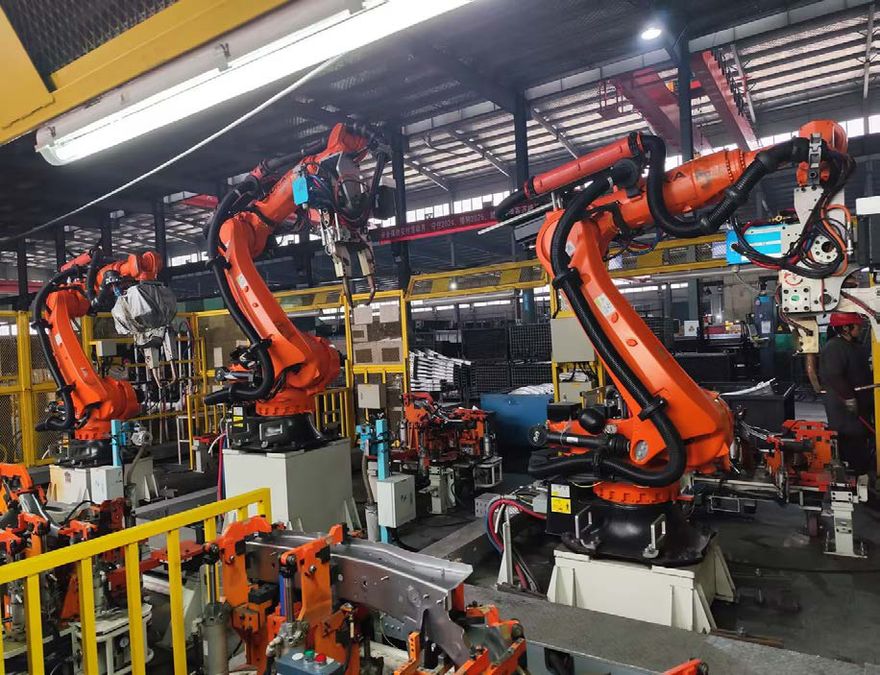 Spot welding
A barrel route for a concentrated welding cell
A KUKA spot-welding cell recorded with a Series 4 barrel configuration. The public data provides the route type and process context; final diameter and geometry remain project-specific.
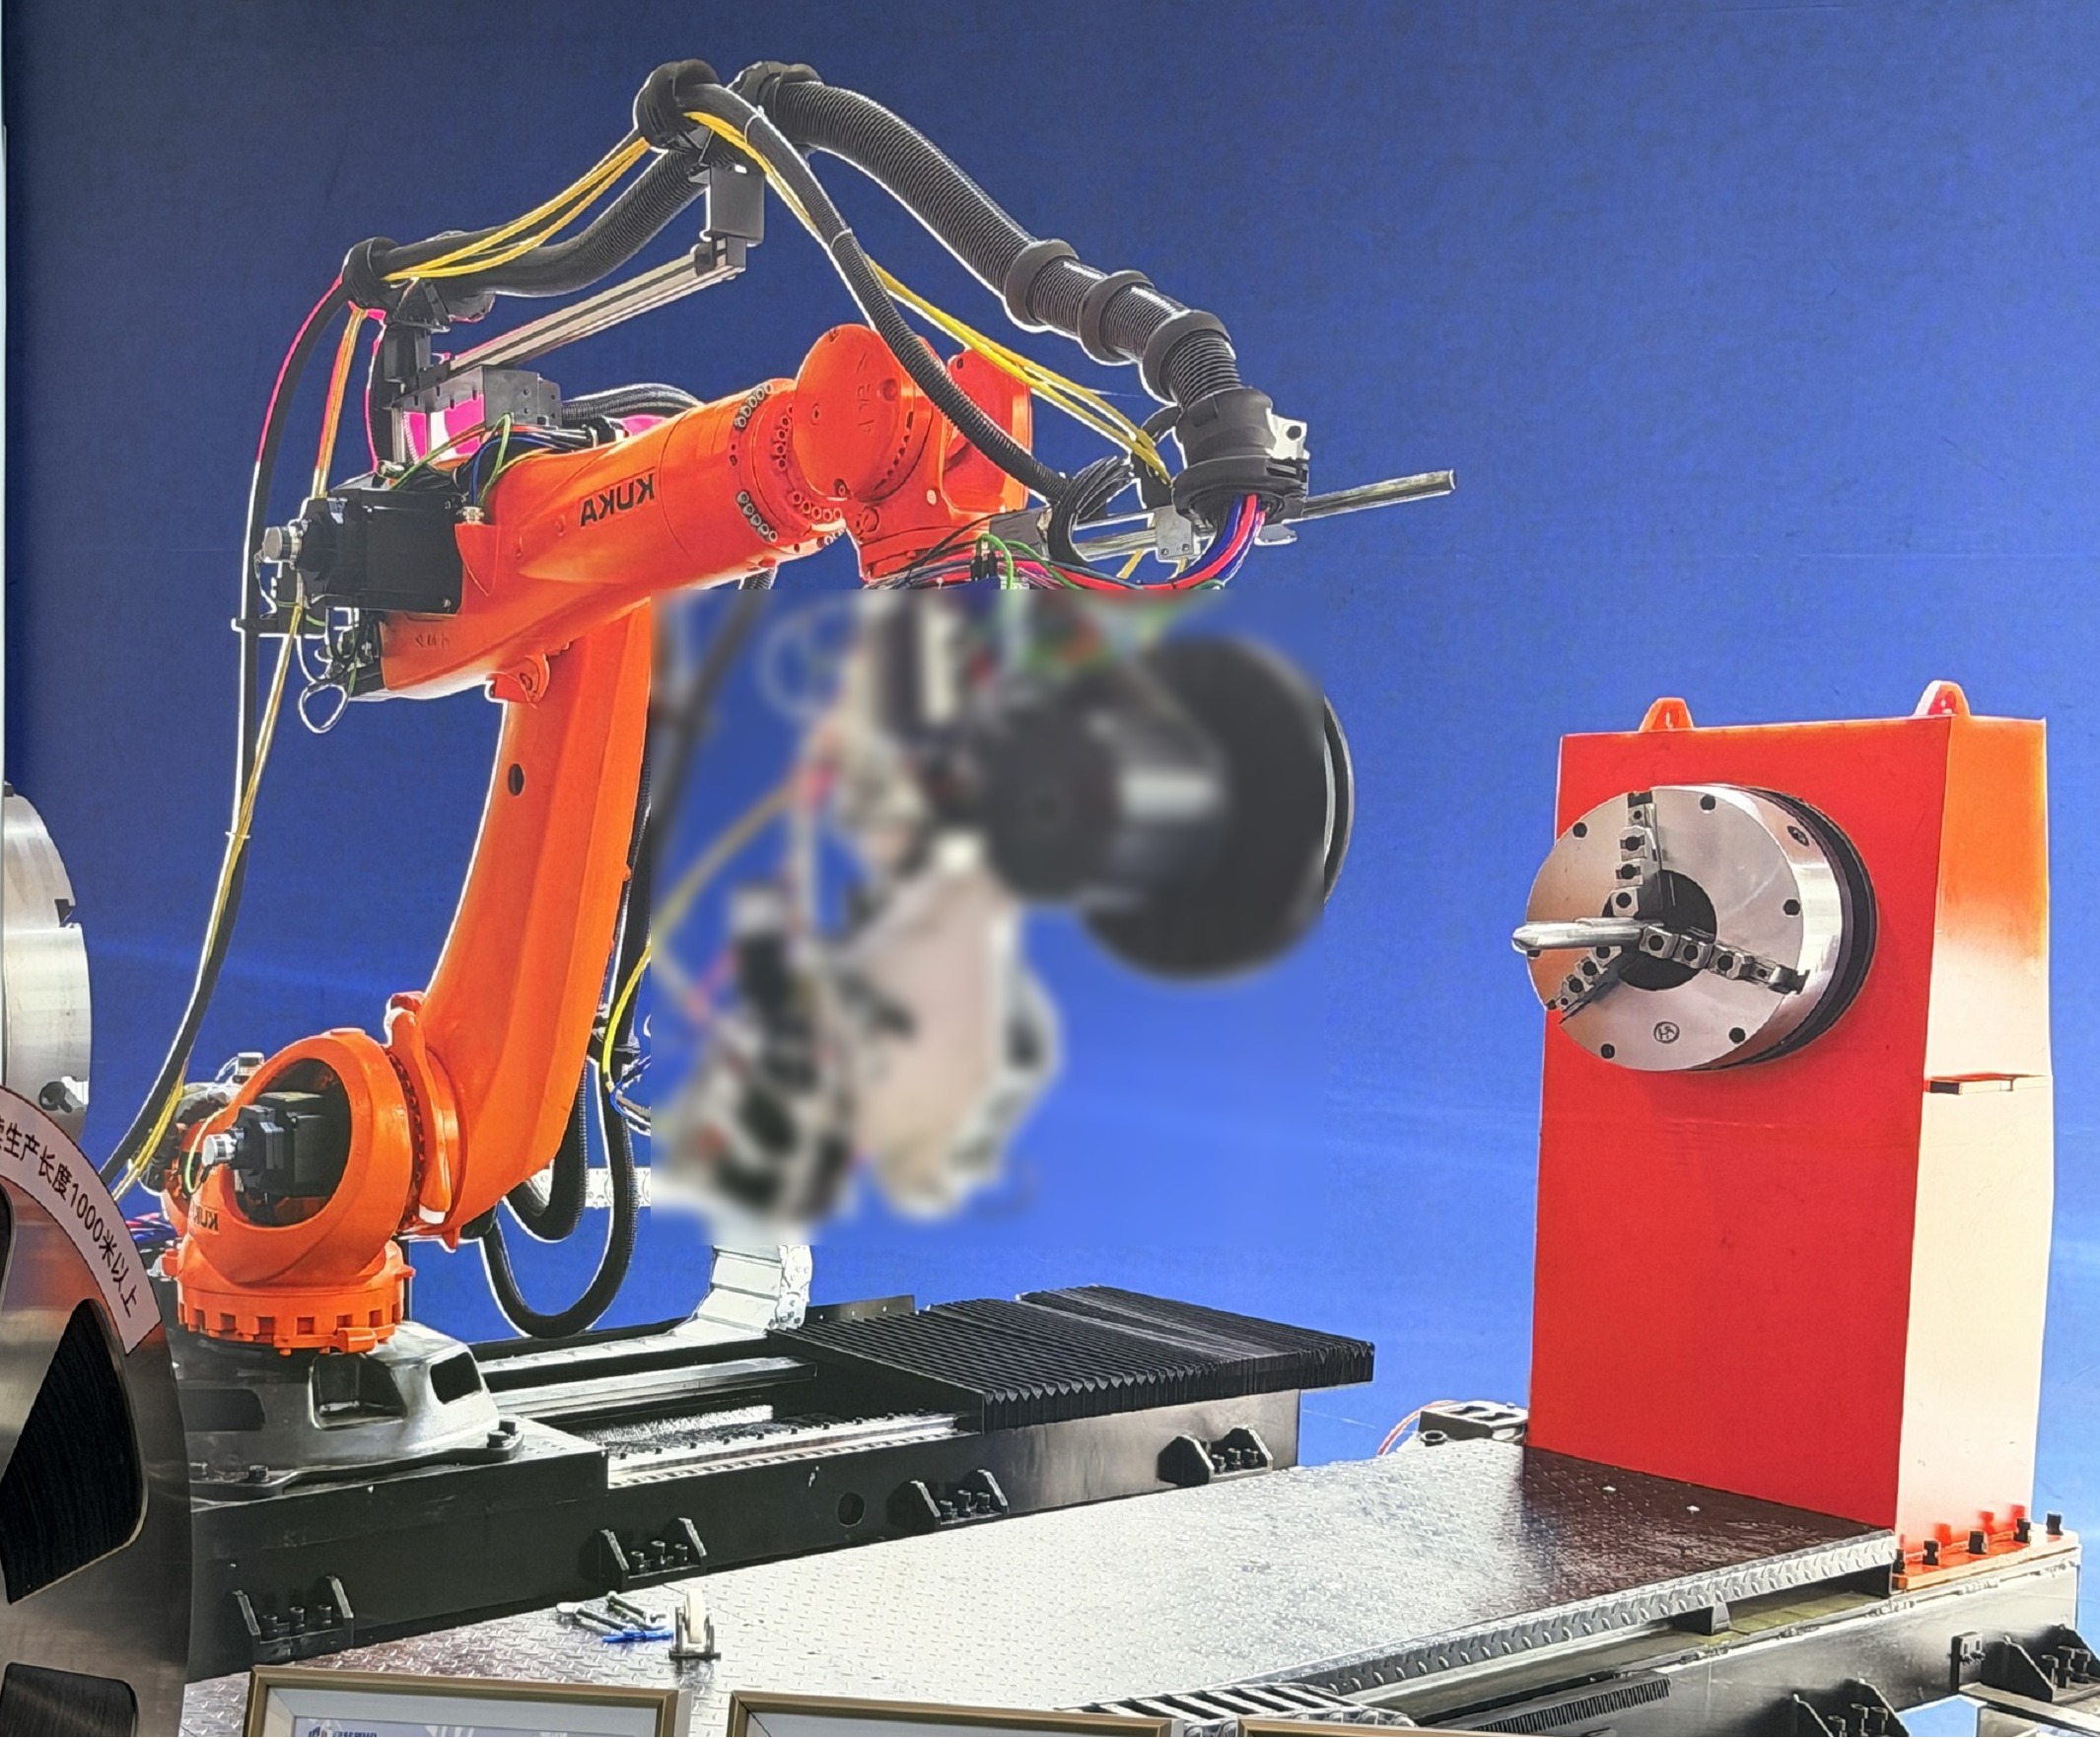 Specialist
Two hose paths, one moving envelope
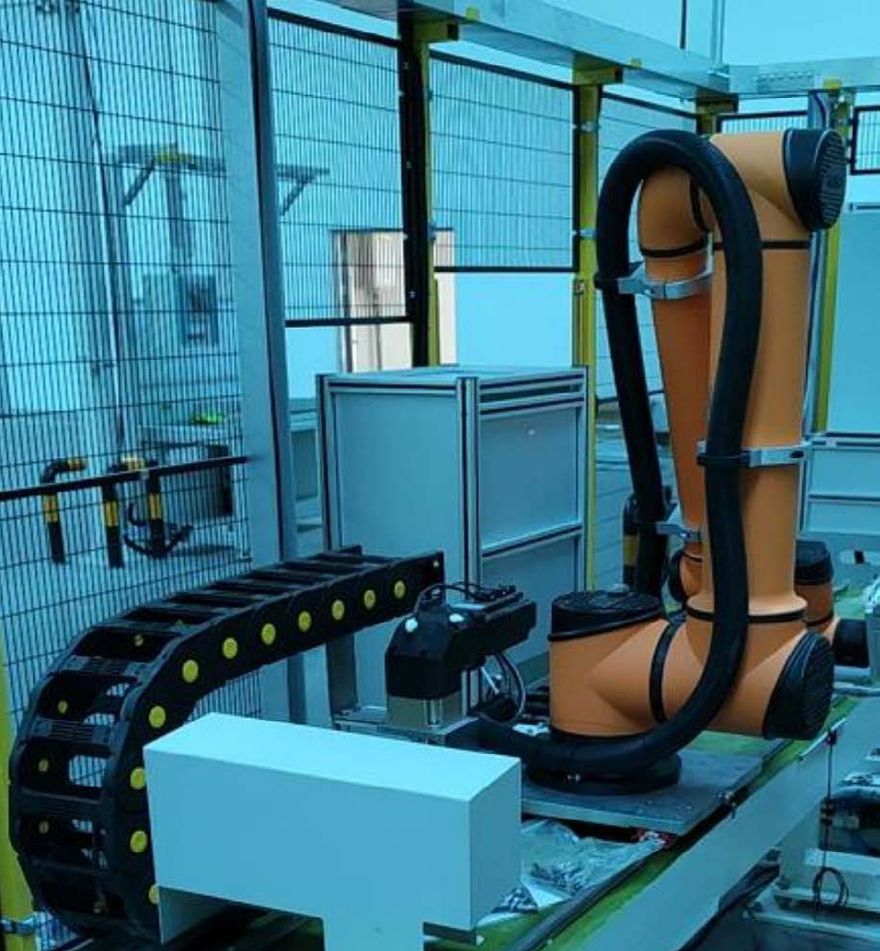
A specialist thermoplastic placement and winding application recorded with a 48 + 70 dual-hose Series 4 telescopic route on a Comau N-170-3.0.
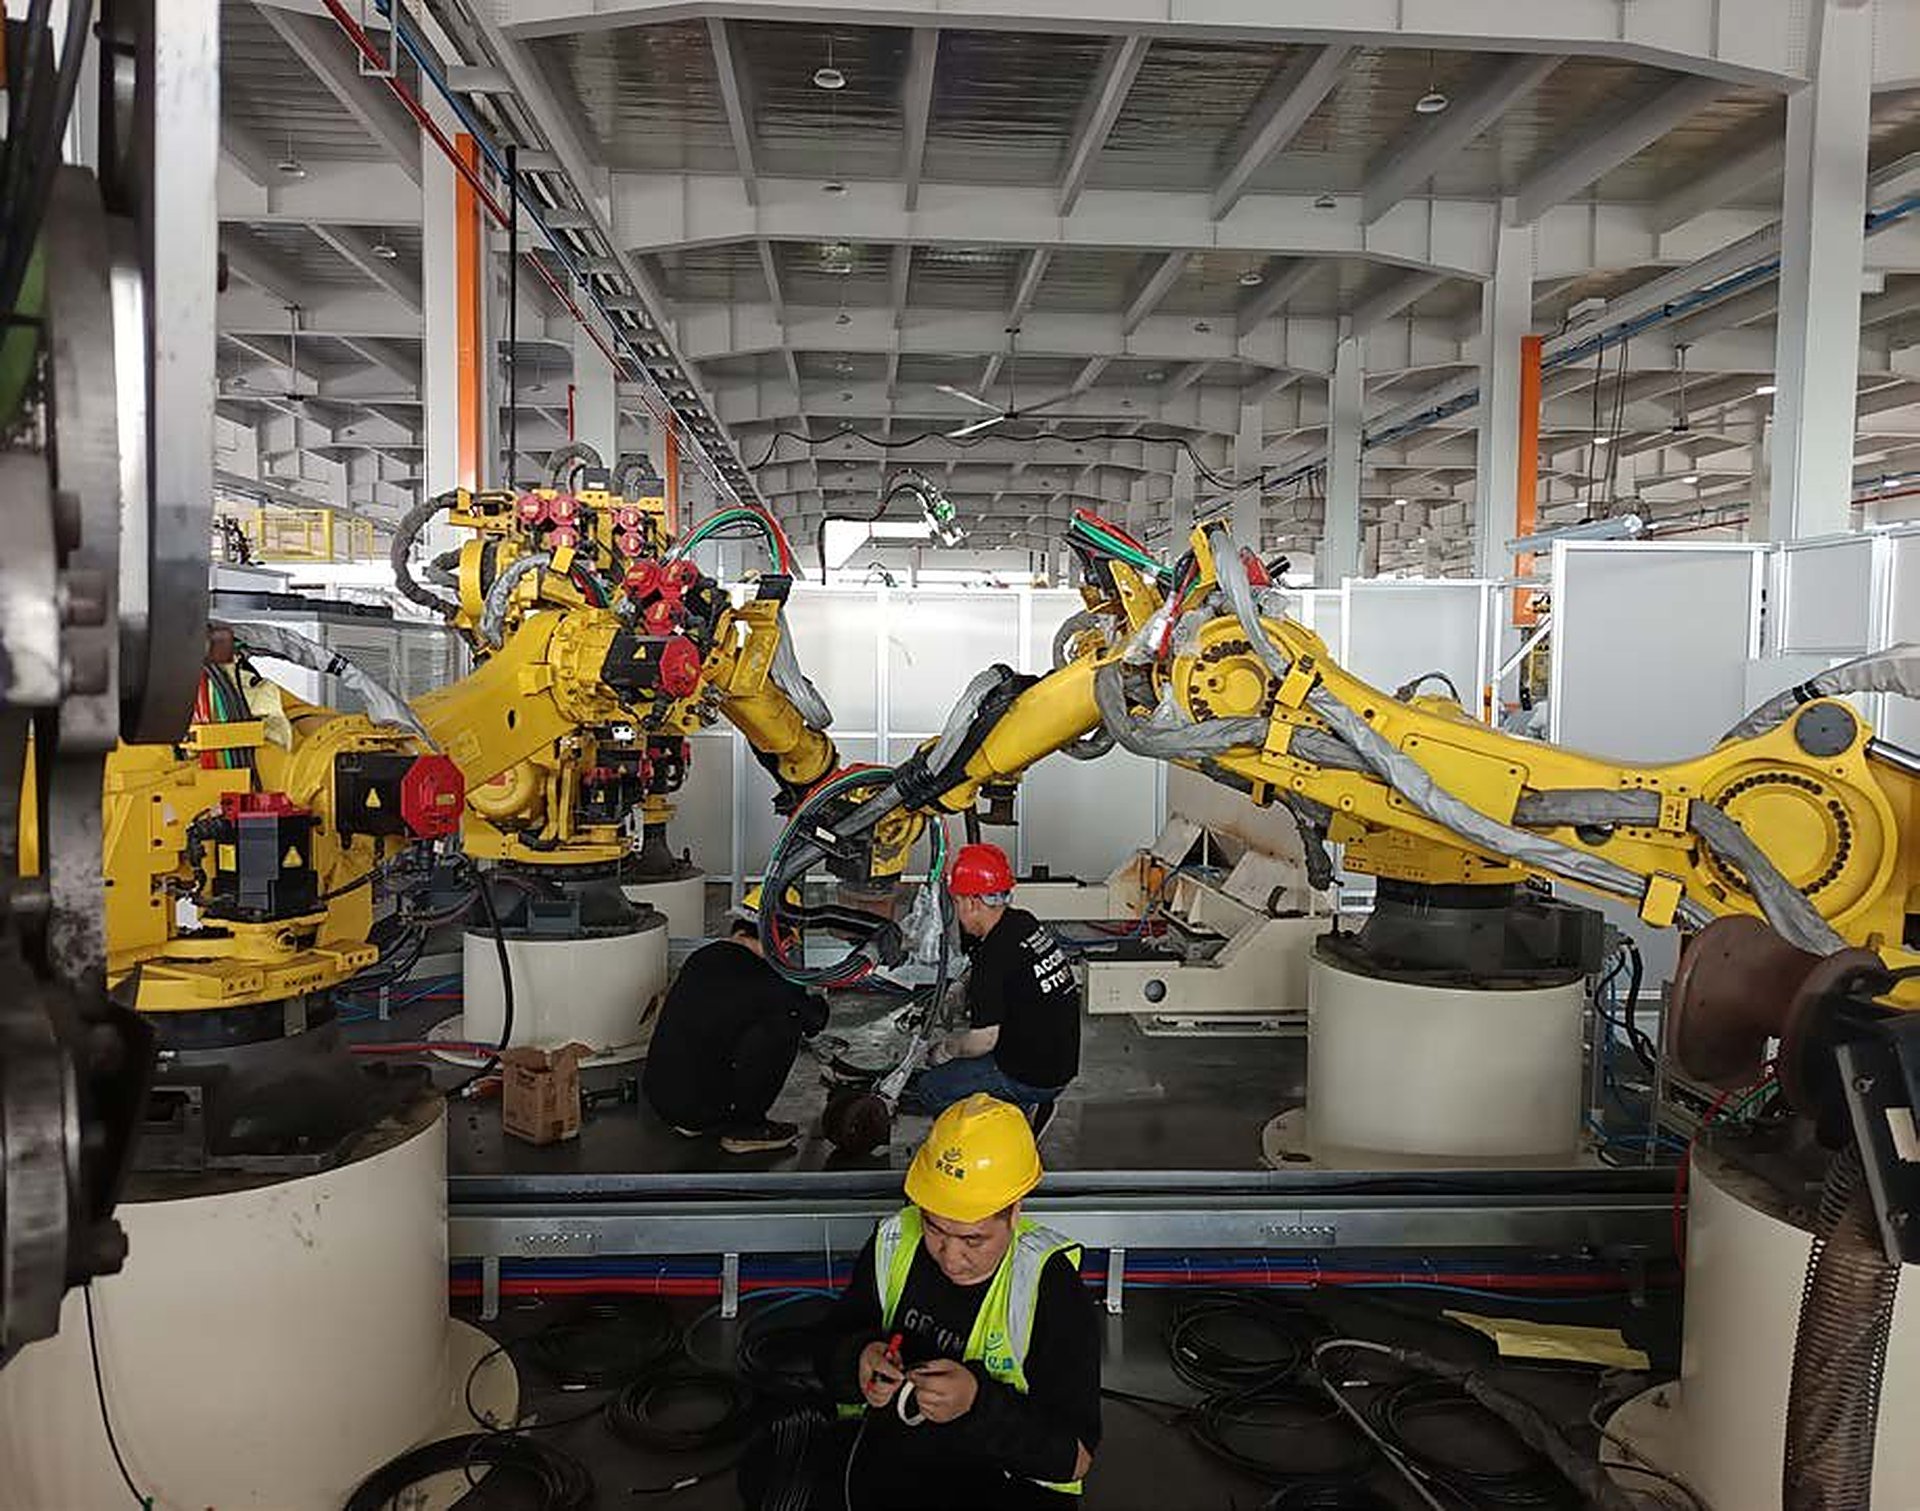 Rotary reference
A long-running rotary reference
A public 2014 record using a Series 2 rotary bracket on a FANUC R2000iA 210F spot-welding duty, with spare wear parts included in the record.
 Rotary handling
Rotary support on a long-reach handling cell
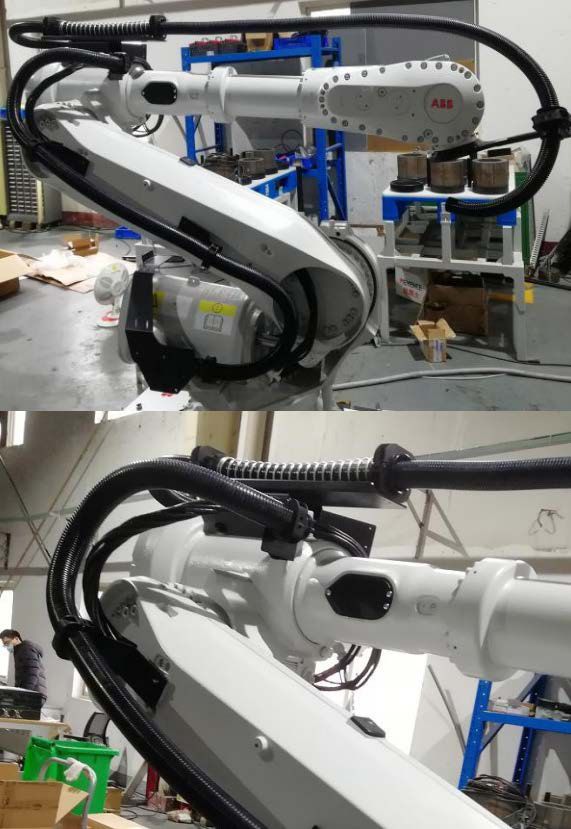
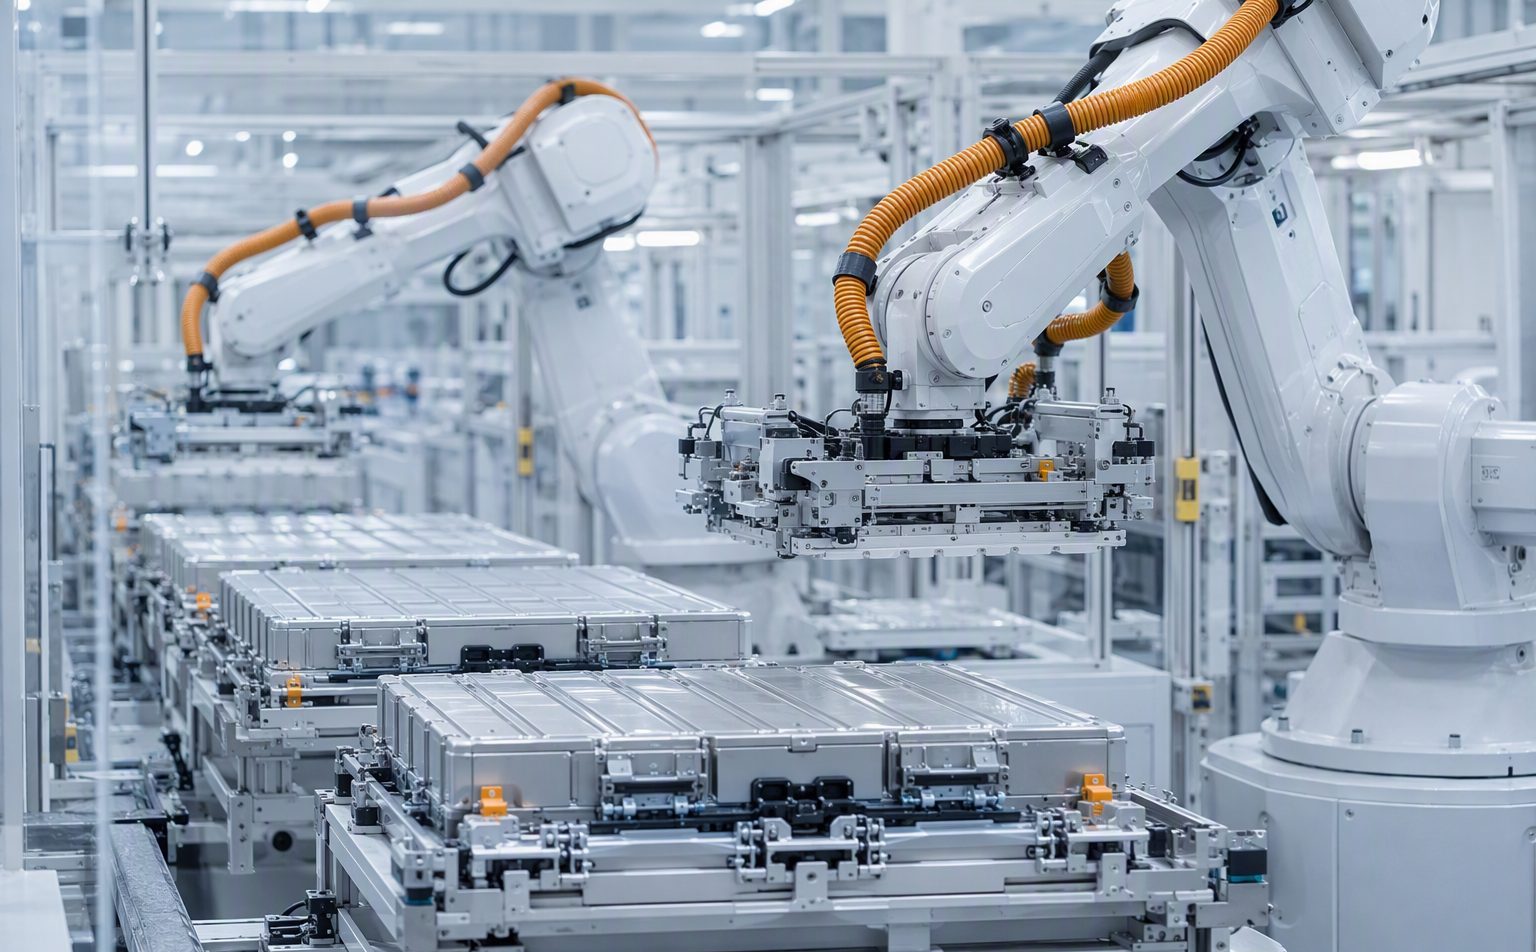
A public 2023 record using a 48 mm Series 2 route on an ABB IRB 6700 handling application. The record is useful for the route type, not as a copy-paste configuration.
What a public record can — and cannot — tell you.
It can show that a robot family, process and architecture have been combined in a real project context. It can also reveal the questions an engineer should ask about tool changes, anchors and service access.
It cannot prove that the same diameter, bracket geometry or spring rate will fit your robot. Those values depend on the bundle, envelope and tool interface. The record is a reference point for a better review.
Ask about a similar dutySend the model. We will map the record to it.
The useful next step is a model-specific review, not copying a nearby case.